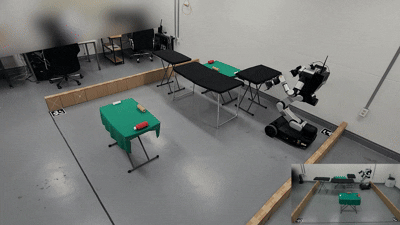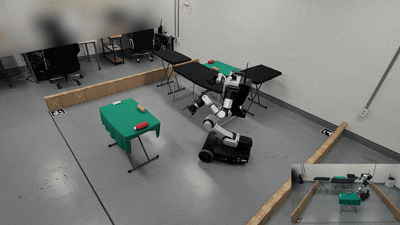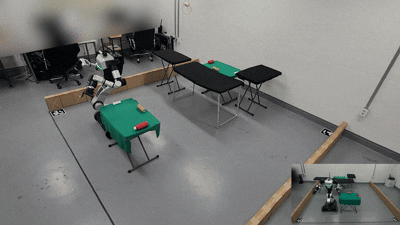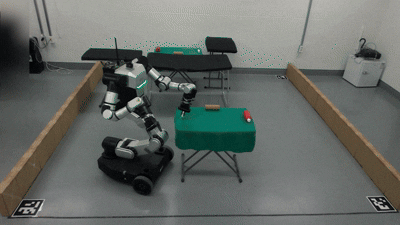
Reachability-aware Diffusion-based Planning for Mobile Manipulation
In Submission
Hello! I'm an M.S./Ph.D. student in Artificial Intelligence at Yonsei University, advised by Prof. Jongeun Choi. My research aims to enable robots to perform complex tasks in the real world, across diverse platforms such as mobile manipulators and humanoids. I'm currently interested in robot foundation models, contact-rich manipulation, and multi-robot systems.
* Equal contribution